Make your own maps and models like this one with your drone. Get Started

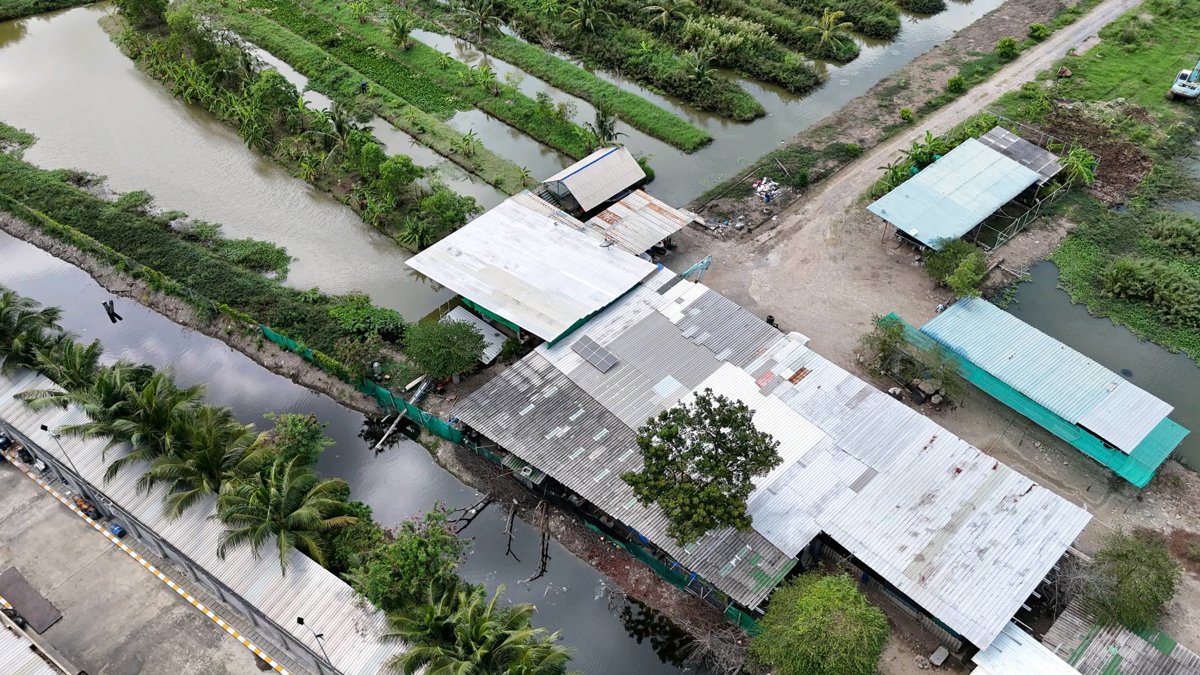
3D Drone Model of ร้าน Gaprao กะเพรา กัอยชา กาแฟโบราณ in Tambon Bang Phli Yai, Chang Wat Samut Prakan, Thailand

Interactive 3D model • Tambon Bang Phli Yai, Chang Wat Samut Prakan, Thailand • Processed October 21, 2026

Compare
Hover model for lat/lng
Viewer tools
Measurement accuracy

Estimated default horizontal accuracy: 3.2 m (typical range 1.5-8 m).

Processed without AerialAlign high accuracy mode.

Context

Notes, photos, and videos tied to places in this model.

Saved measurements

Measurements auto-save and can be removed from here.

Thumbnail preview for 3D Drone Model of ร้าน Gaprao กะเพรา กัอยชา กาแฟโบราณ in Tambon Bang Phli Yai, Chang Wat Samut Prakan, Thailand

Site context

About this 3D model

This page displays an interactive drone 3D model of ร้าน Gaprao กะเพรา กัอยชา กาแฟโบราณ in Tambon Bang Phli Yai, Chang Wat Samut Prakan, Thailand. The viewer above is the primary experience: pan, zoom, switch visualization modes, and inspect the capture without installing extra software.

It can help review roofs and facades, grade and elevation changes, surface materials, vegetation, and overall site layout. The available project data includes the browser point cloud, textured OBJ model when available, orthophoto, and LAZ point-cloud archive, depending on the outputs generated for this model.

Processed
October 21, 2026
Location
Tambon Bang Phli Yai, Chang Wat Samut Prakan, Thailand
Center coordinates
13.61654° N, 100.67670° E
Capture type
Interactive 3D point-cloud model

Common questions

Yes. When downloads are available for this capture, use the Download menu for the textured OBJ model, orthophoto GeoTIFF, or point-cloud archive. Some files may require signing in.

It is useful for documentation, inspections, planning, progress tracking, asset review, and browser-based visual context for a site or property.

Overlapping aerial photos were processed into web-viewable photogrammetry data. Coordinates are shown from the project location and, where available, from the point-cloud projection.